As for the thrust line, the builders manual indicates to place the
thrust
line level at WL01.  It should be the same for this engine.

Charlie Smith
KIS Cruiser 4021
I have to relate that to your numbers charlie. which one of these
dimensions
corresponds to the WL01?

Paul
Charles Smith wrote:
snip. . . .

 0            6.438
Paul,

Please put this one out so Bill can verify my numbers/methodology.

On my firewall, the vertical center line and the bottom of the lower
fuselage joggle are marked.  The bottom of the joggle is WL-1.25.  Measuring
up 1.25 inches gives WL00.  Measuring up another inch gives WL01.  This
point exists 9.25 inches below the top of the firewall.  If you use the (0,
6.438) top cowl datapoint as a reference, the thrust line would intersect at
a datapoint located at (0, -2.812).  I would use the firewall dimensions and
find the vertical center.  Then come down on that vertical center 9.25
inches from the top and push a line out normal to the plane of the firewall.
This will be the thrust line.  The manual also states to put in 1.5 degrees
of right thrust into the mount for a conventional engine.  I think this will
be ignored in this case.
I hope this is what you needed.

Charlie Smith
KIS Cruiser 4021
I think that is the last piece of the puzzle charlie. Thanks will work on
the cowl 3D now.


Paul Lamar
-----------------------
I measured today, and my mark of WL + 1 is 9.5" below where I mark my
outside surface of the cowl top. When you take in the thickness of the
flange, etc. I believe that Charlie's measurement of 9.25 is consistent with
mine.

Another measurement. My E-shaft drive pulley nut (face) is 3-5/8" from
firewall surface.

My cross beam is 19-7/8 " from the firewall (probably shooting for 20".

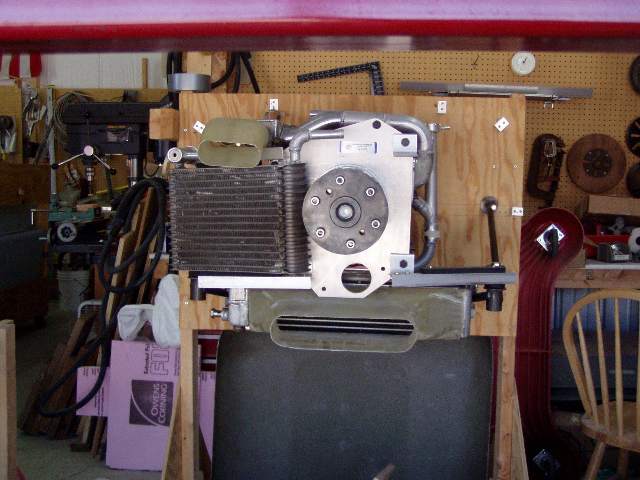
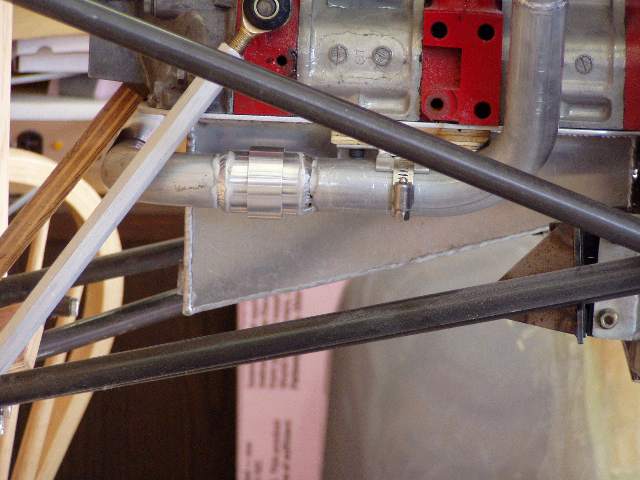
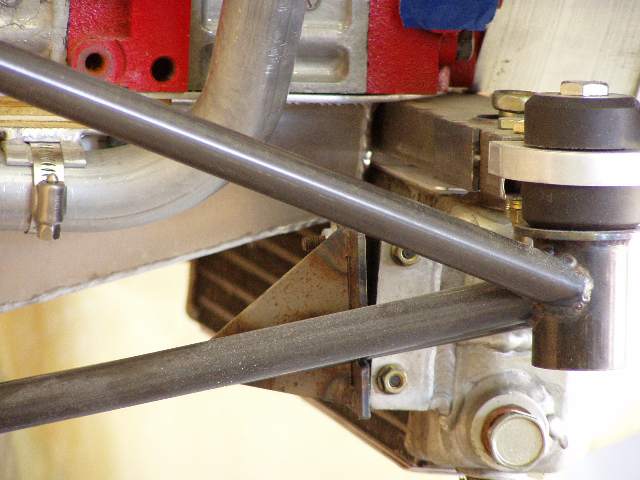
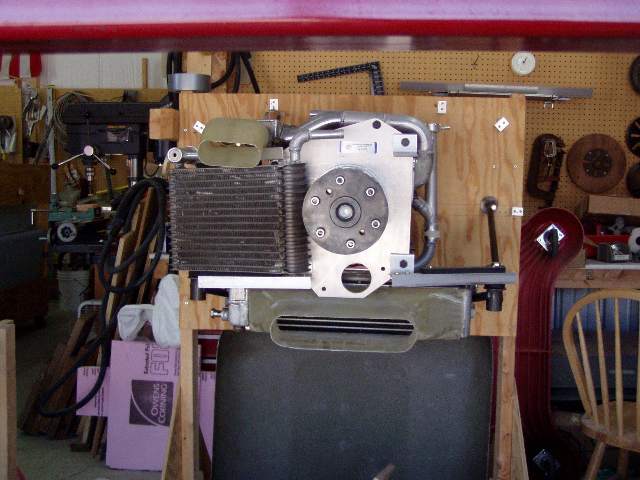
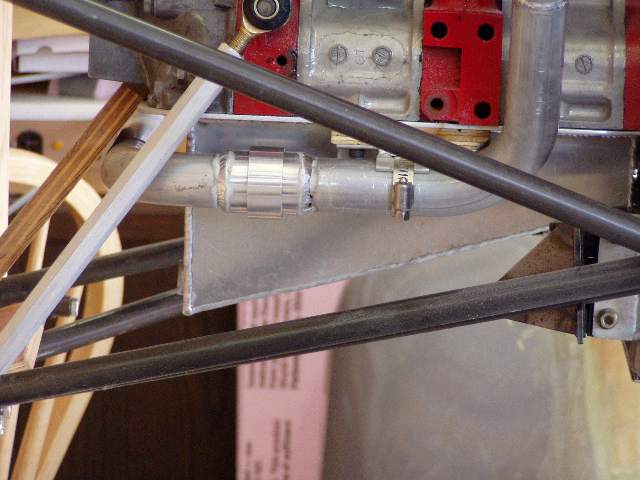
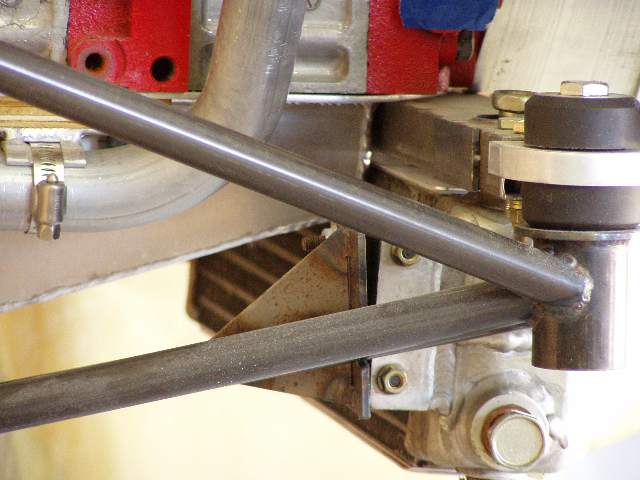
I am enclosing some pic's that show the oil cooer between the motor mounts,
and the clearance of the oil pan. My intent was to have the starter location
in the hole that Tracy provided.

Bill Schertz
KIS Cruiser # 4045
The Rotary Engine NewsLetter.  Powered by Linux.
ACRE NL web site. http://home.earthlink.net/~rotaryeng/
Copyright 1998-2004 All world wide rights reserved.