Hello All,
Here's a question to the group for those who own a Ross PSRU. I own a
Ross 2.17 to 1, and I am tying to solve one of the issues regarding the
"drive shaft" from hitting or bouncing off of the thrust bearing – I'm
sure people who own such a unit knows what I mean. I found some
solutions on the net but I'm wondering if anyone else in this group has
a suggestion, possibly a simpler solution.
I've heard comments of "just sell the unit and get another one" but I'm
not sure that I need to go to that extreme. My primary two reasons are
1 – The unit is an integral part of my engine mount and 2 – A
replacement would probably cost me two to three thousand dollars (if not
more to redesign my engine mount) – just to note, I purchased the plane
from someone else, so it's not my original idea….
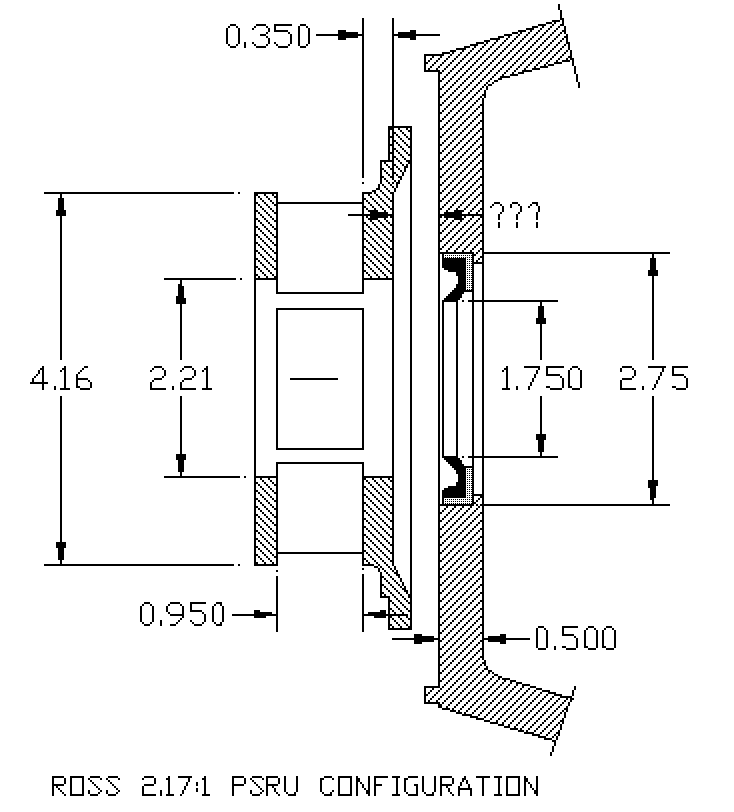
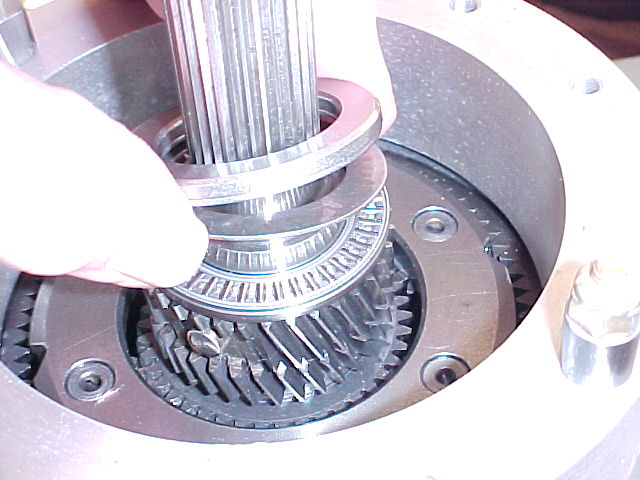
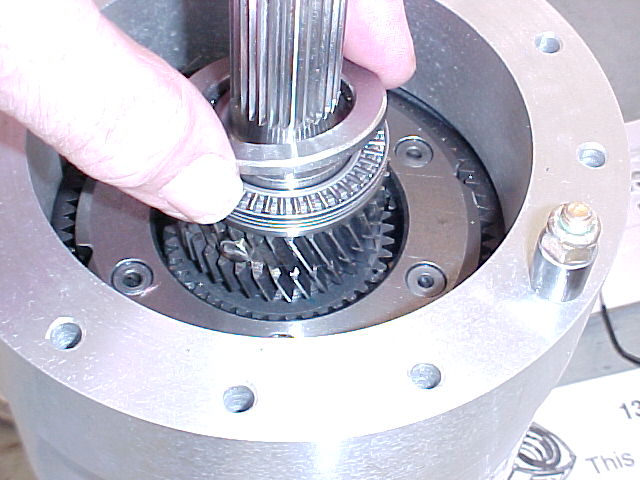
I've included a few pictures of my setup.
Cheers,
Burck Hantel
FYI:
A fellow named Phillip Johnson explains what is going on a little better
then I can so I am reiterating his explanation here:
http://www.canardzone.com/members/PhillipJohnson/Engine/psru.htm
"Breaking open the PSRU reveals the working parts, namely the planetary
drive. Under load conditions the input shaft is drawn towards the output
shaft to which the propeller is attached. A thrust race, takes this load
quite satisfactorily. When in a decent the propeller drives the engine
and the input shaft is forced to move in the direction of the engine.
The ROSS design does not provide a true thrust bearing to support this
load, moreover the load is taken by a conventional sealed ball race
contained within the lightweight flywheel. This bearing is there to
accommodate the slight differential rotational rocking motion
encountered as a result of the torsional isolator mounted on the
flywheel. A resonant condition is set up when operating near idle when
the engine drives the propeller followed by the propeller driving the
engine. There is considerable chatter at that point and the input shaft
is hammered back and forth between the thrust race illustrated below,
and the conventional bearing previously described. The bearing begins to
break down and the end movement increases only exacerbating the
problem."
---------------------------------------------------
I under stand the problem. The next message will offer some ideas.
Paul Lamar ...No rotor no motor.
Here are some suggested solutions.
--
Paul Lamar ...No rotor no motor.
Hi Paul,
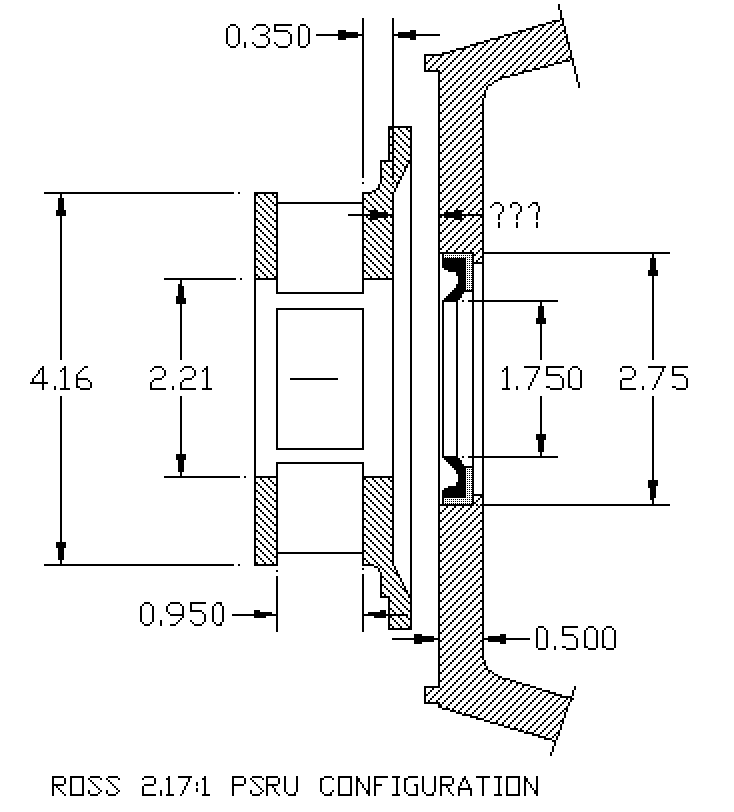
Thanks, this will help a lot. I've seen Jerry's design from another
website, but I never did find a profile picture like the gif you sent --
that's the picture that pulls everything together.
My only concern, is there enough oil lubrication to the thrust bearings
and oil seal? -- i.e, can oil find it's way through the layers of
washers/bearing races/thrust bearings/shaft seal?
Cheers and thanks again,
Burck
It seems to work fine. Needle thrust bearings don't like high
RPM so the trick is to use several back to back. Then each one
rotates at only 1/3 of the shaft speed.
The big advantage is they are cheap. Tracy went through
an exercise as I recall where he at first tried a roller thrust
bearing that did not work. Then he tried a ball thrust bearing.
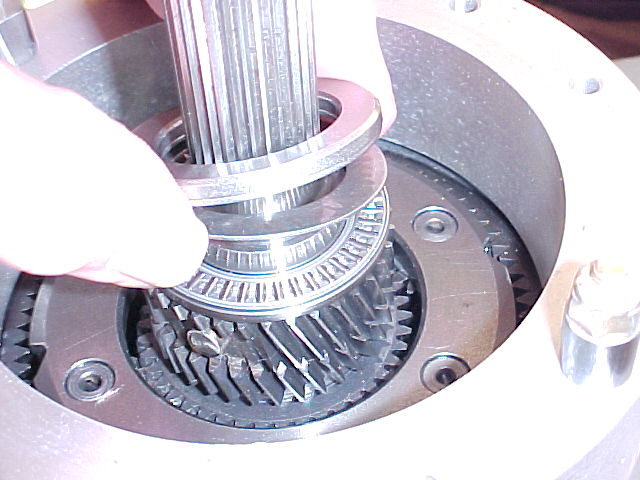
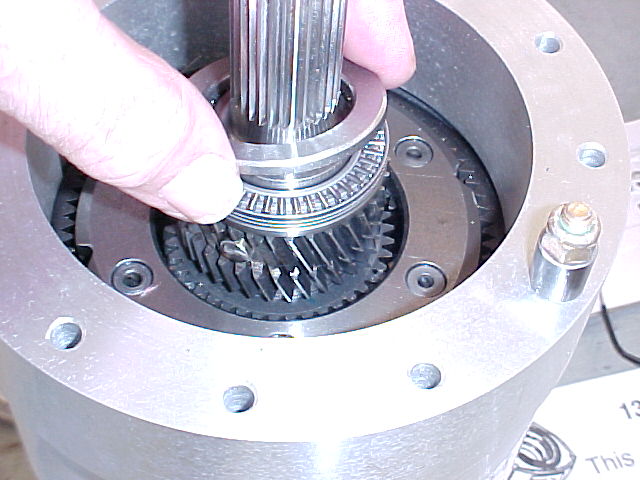
Finally he went to three needle thrust bearings like late model
Ross boxes used.
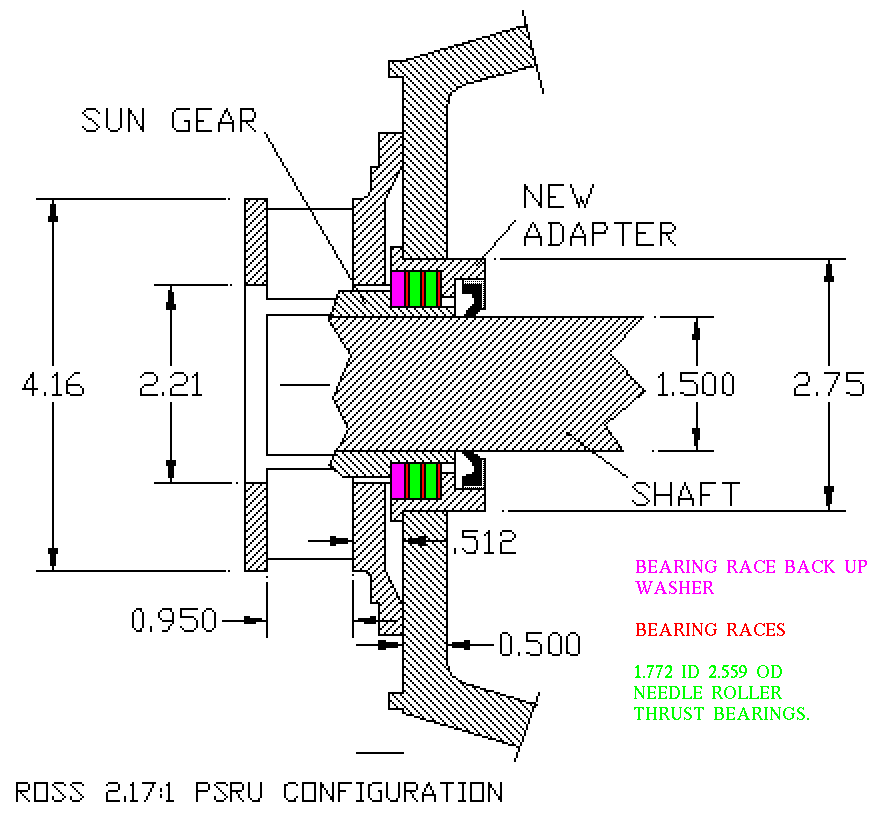
Here are some pictures of Tracy's 3 needle set up.
You need to get into the box and measure how much clearance
you actually have between the planet carrier and the bell housing part.
Do this with modeling clay. Put an over size lump of
clay in there and then reassemble the box. Take the box
apart again and measure the thickness of the clay.
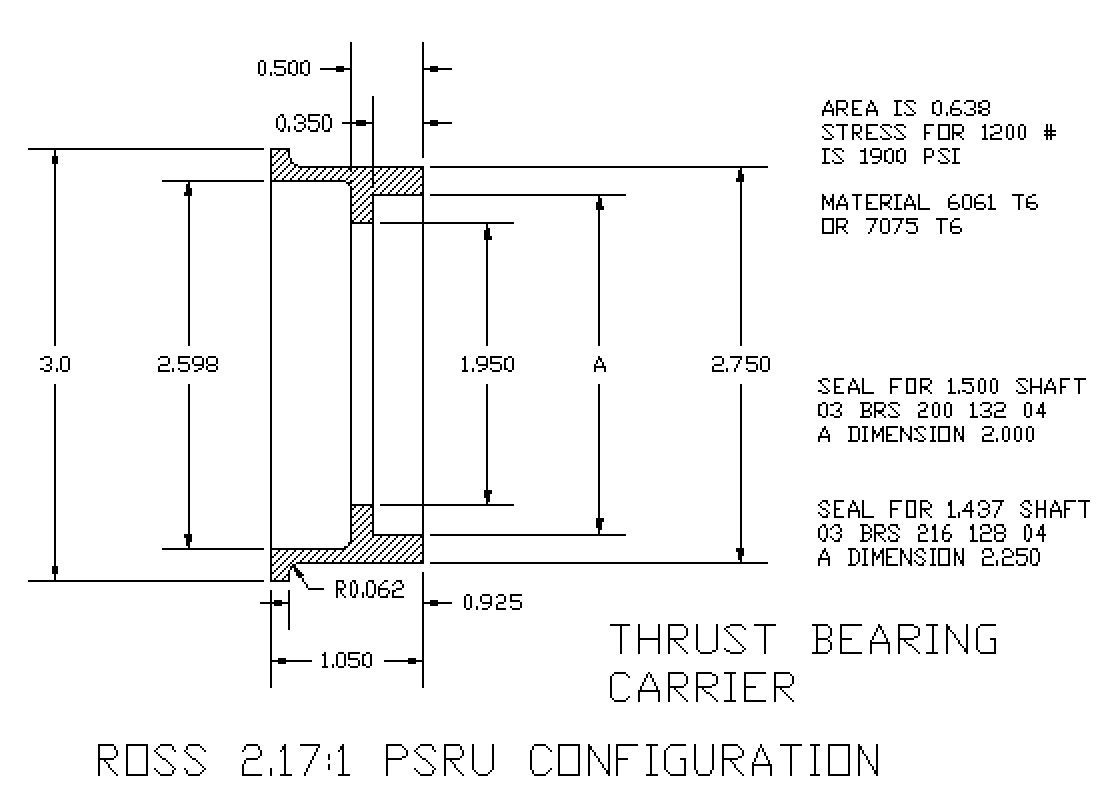
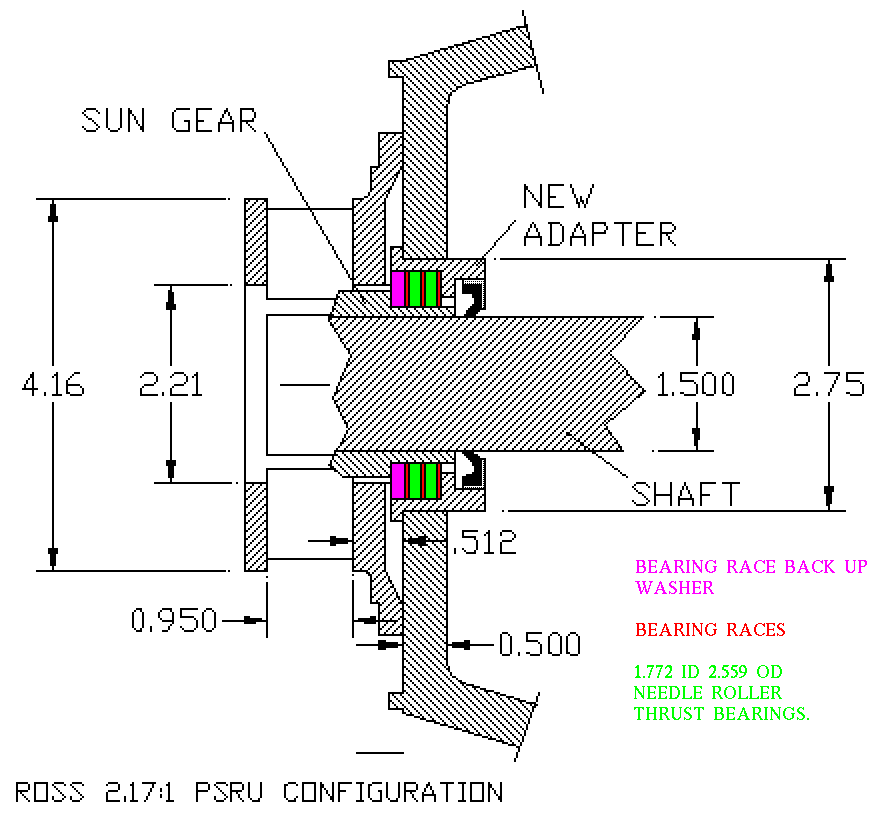
Third attach.
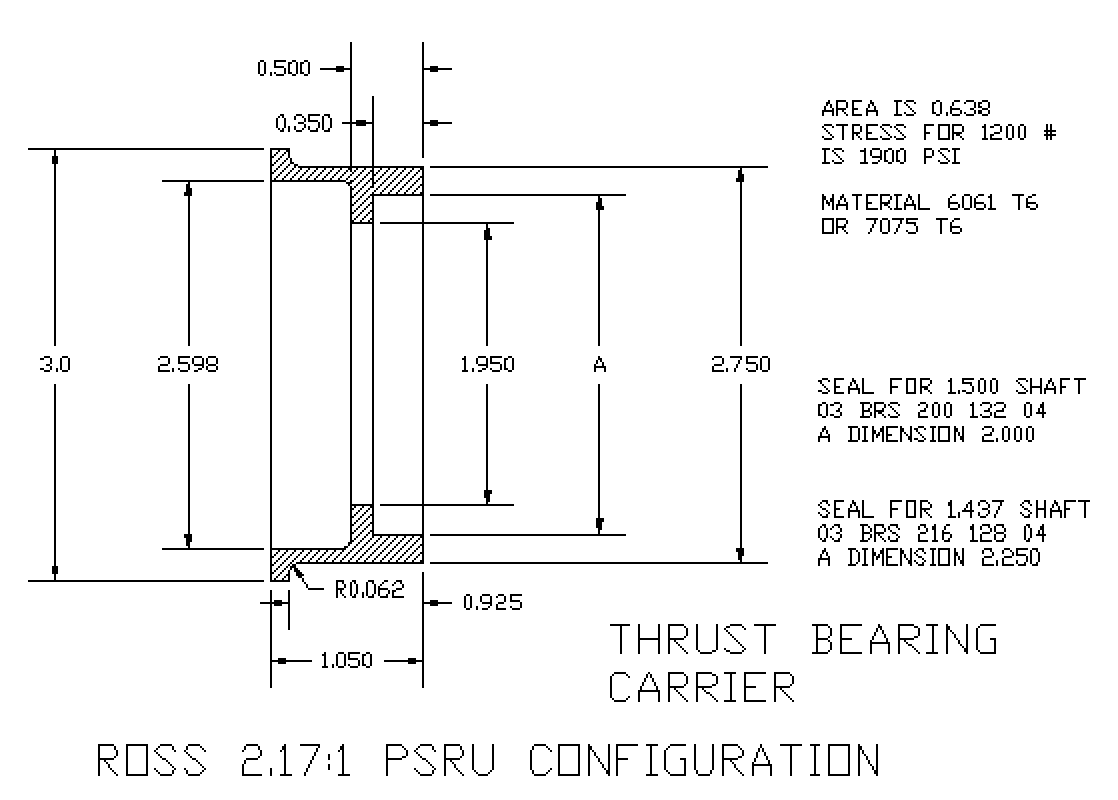
Now the job is to fit three needle bearing in there somehow.
That is where the adapator comes into play.
Fourth attach.
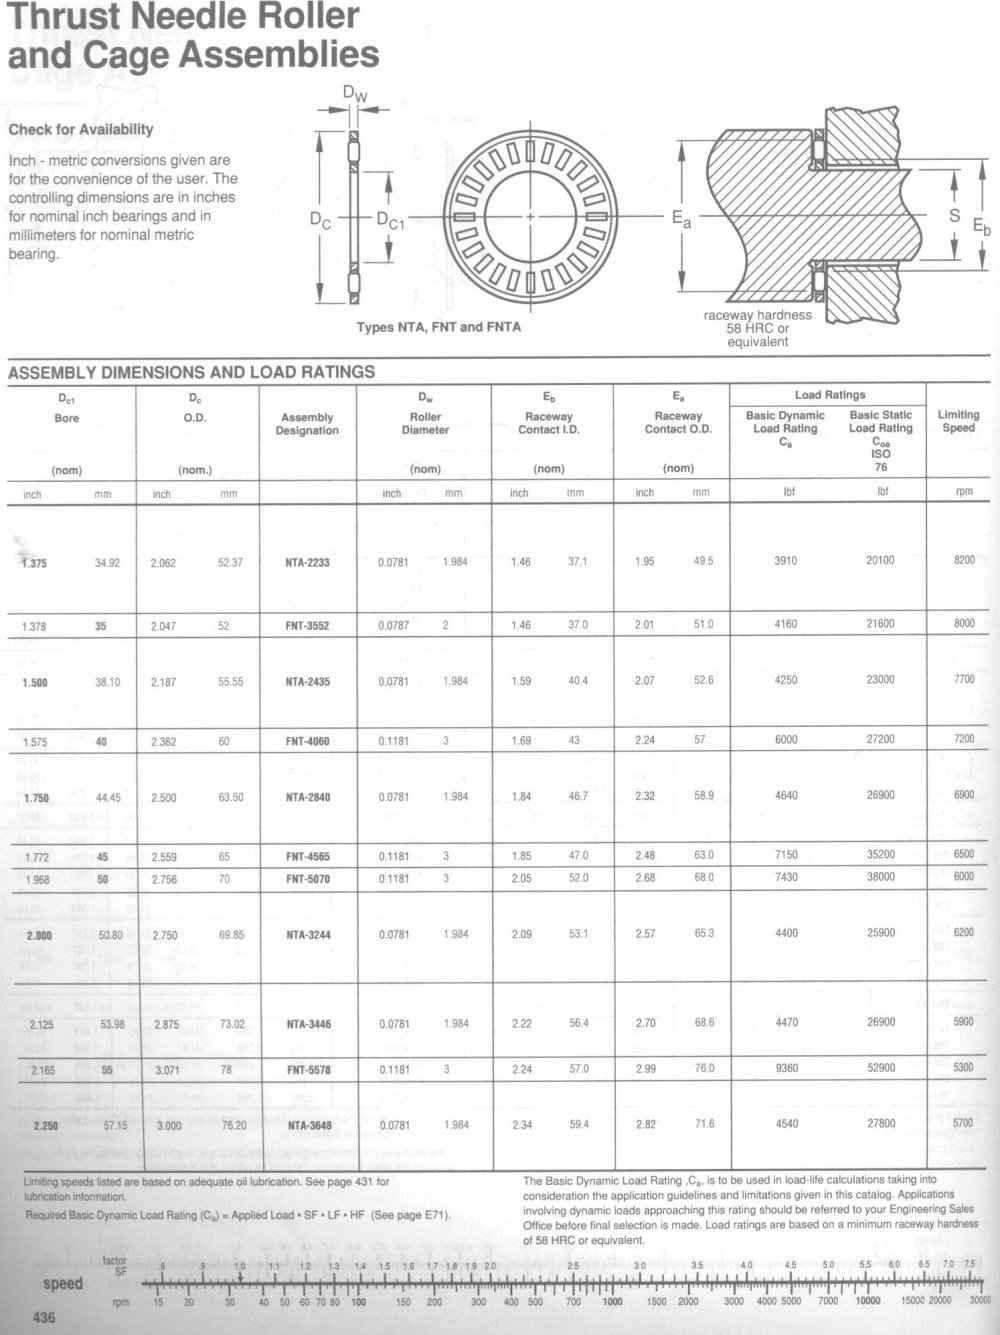
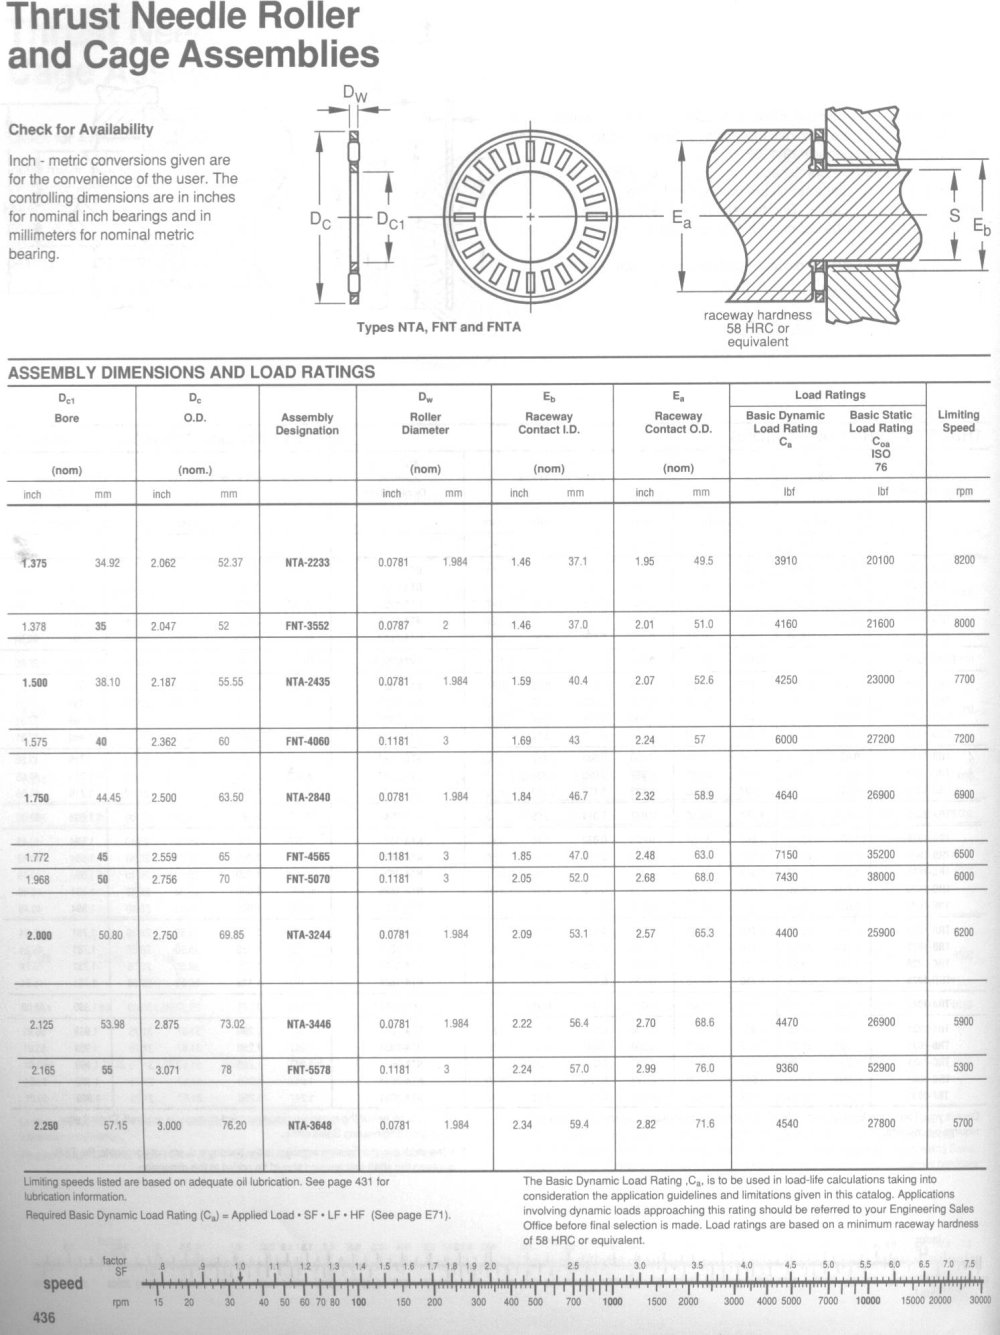
Last needle bearing dimensions and load ratings.
Paul Lamar ...No rotor no motor.
The Rotary Engine NewsLetter. Powered by Linux.
ACRE NL web site.
http://www.rotaryeng.net
Copyright 1998-2006 All world wide rights reserved.