This is stunning in it's simplicity.
since I am using the proven Ford A4OD six pinion planetary in a differential
mode the total gear reduction is 6.34:1. The ring gear is rotating
in one direction and the planet carrier is rotating in the other.
As long as both props have the same drag the RPM's of each prop
will be equal. With an engine RPM of 8500 the rotors will
be turning 1340 RPM. We can probably use a 13 to 14 foot diameter
rotor at this RPM. The red line on the RX8 engine is 9000
RPM and a P-port RX8 engine will be making close to 300 HP
or more at 8500 RPM. We will find out in a few weeks
as I am building such an engine as we speak
The over all diameter of this gear box is only
about 6.5 to 7 inches. It will have it's own oil
supply as it is on the very front of the airplane and
the engine is at the very rear for weight and balance reasons.
There is a stock RX8 carbon fiber drive shaft connecting the two.
The first 3D is with gear box housing.
The second is without gear box housing.
The third is with the aft prop shaft.
The gimbal is centered on the U joint which is a requirement.
The gimbal allows the props to be pointed in any direction with in
limits. The same as the Air Scooter. This will allow maneuvering in landing
and take off mode and help with the transition to horizontal
flight and back to vertical flight.
Did we luck out or what?
Paul Lamar ...No rotor no motor.
Paul,
Interesting idea. In theory it should work, But on initial startup, both
rotors could turn the same direction. you will need to build a test rig and
test the theory. Not being a forced synchronization, it may be yaw unstable
in hover.
Larry
Yes that is true. I hadn't thought of that. Thanks for thinking of that Larry.
Let me put my thinking cap on and see if I can come up with solutions
to these problems.
Once they are rotating the highest speed rotor tips will run into a transonic
brick wall transferring the torque that is left to the slower rotor. If we
make the rotors variable pitch the yaw forces in vertical mode can be
controlled changing the rotor blade pitch individually.
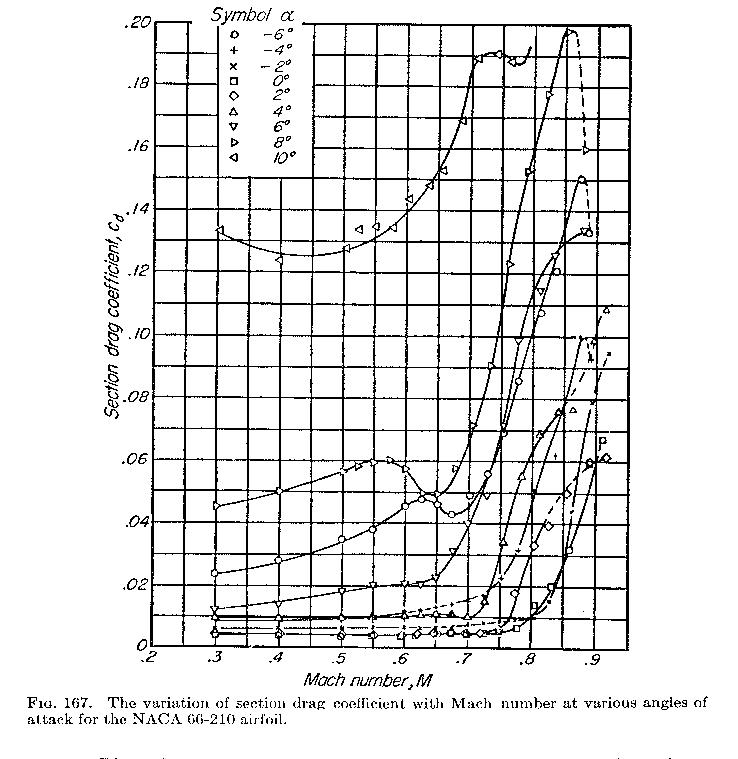
Here is a chart of drag coefficients of an airfoil as a function
of angle of attack as it approaches the speed of sound. Small changes
in pitch make large changes in tip drag.
Also one rotor can be feathered on start up to insure they rotate
in opposite directions. However one blade would be going backwards
so that might be sufficient torque load difference so the unit goes into
counter rotating mode.
BTW I am thinking of using an infra red or laser link and slip rings for
power to control the pitch on the front rotor electrically. Solves a lot of
mechanical problems and saves a bunch of monkey motion pitch changing
parts. It could also be be done super imposing low level pulse width
modulation on the 12 volt power slip ring circuit. The power slip ring
would have to be located in the gear box working on the back side
of the planet carrier. This trick works on fuel pumps embed in
gasoline.
In that case
a stock high torque model airplane servo can be used to change
the pitch. The Kaman used an aerodynamic flap on the back of the
blade to change pitch.
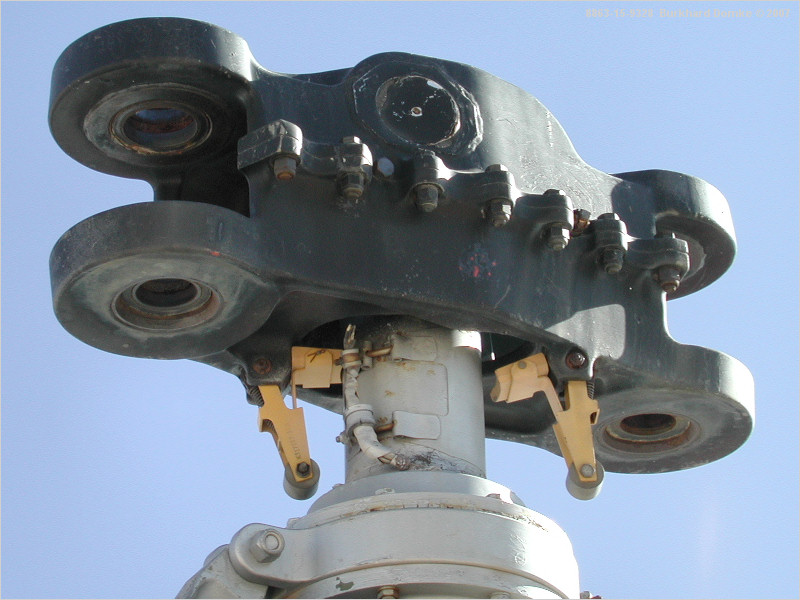
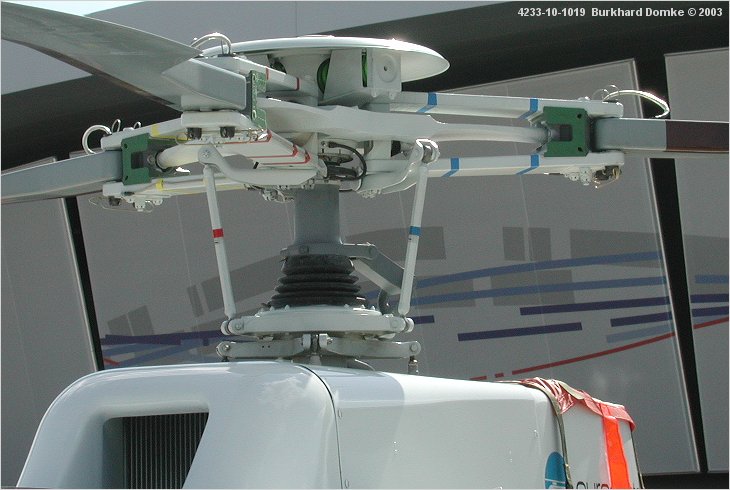
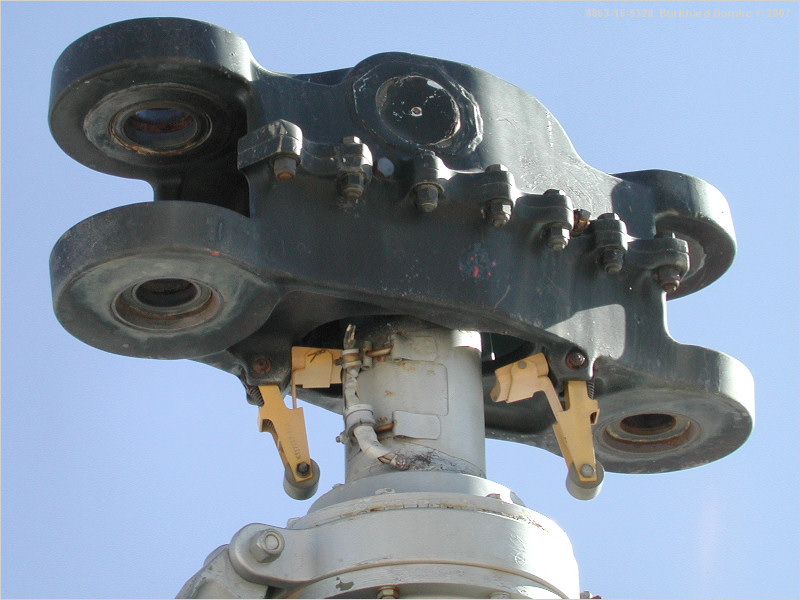
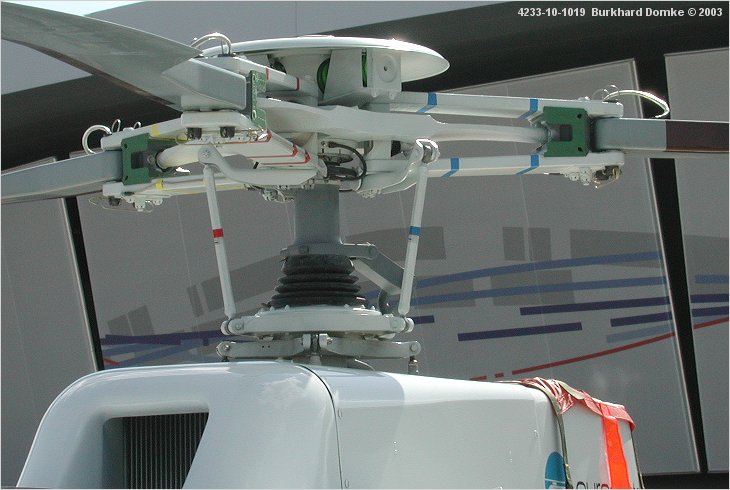
http://www.b-domke.de/AviationImages/Rotorhead.html
"Kaman H-43 Huskie
Two-blade contra-rotating intermeshing twin-rotor with servo-flap control.
Rotor blades are attached to hub by drag hinges only, the servo-flaps
eliminating blade pitch change and associated bearings. Movement
of servo-flaps twists the blades with the natural resilience
of the blades used to obtain torsional deflection."
I don't like twisting the blades because IMHO it does not lead to
the optimum pitch distribution along the length of the blade.
I could be wrong about this as helicopter blades are not very
torsional stiff to begin with and they may have a mind of their
own when it comes to local pitch. Kaman may be on to something
in this regard. Kaman's do have a reputation of generating a lot of
lift however so some of that could be due to no tail rotor
sucking engine power.
I would rather use a torsionally stiff carbon fiber blade
rotating around a bearing in the hub. The aerodynamic servo flap
can still be used to control pitch.
Since we will not be flying forward in helicopter mode for long the
leading and lagging hinges can be done away with. Same goes
for the flapping hinges. I think we can use GRP for the
hub. Same as several European helicopters use. GRP has high
tensile strength and a low modulus of elasticity allowing it
to flex without failing. Same as the Long EZ main landing gear.
Paul Lamar ...No rotor no motor.
The Rotary Engine NewsLetter. Powered by Linux.
ACRE NL web site.
http://www.rotaryeng.net
Copyright 1998-2006 All world wide rights reserved.