You can only climb straight up for a few seconds so you better
start pitching over right away or its going to hang on the
prop. This program assumes you are going to pitch over right
away. If you don't the velocity will drop to near zero and the
the airplane will stop climbing vertically. It also assumes the
prop
pitch is adjusted for maximum thrust at all times.
Top speed will be limited by the rotor tips going supersonic.
Paul Lamar ...No rotor no motor.
Paul,
The way I read your data, at takeoff, your are making 6.66 lbs of
thrust per
hp. At 11,000 ft you are making 9.18 lbs of thrust per hp. I
think that
portion of your formula is inverted, as the other attached chart
shows the
prop loosing thrust with airspeed (and air density), not gaining.
The other thing is the velocity appears to be gaining at a steady
rate and
it should be decaying in proportion to the vertical g force.
As a reality check, look up the gross weight of a 300 hp helicopter
and what
it's vertical performance is.
Larry
Thanks Larry. I'll check it over.
--
Paul Lamar ...No rotor no motor.
Thanks Larry for your help in finding those errors and thinking
about it.
I lost focus there for a minute. This is not altitude. It is
distance traveled
through an arc over.
I added altitude compensation to the HP by mistake. I removed it in
this version.
I am assuming the aircraft is going to pitch over once it reaches
flying speed around 70 MPH and at around 1000 feet so this is
mostly
a crude
approximation of the vertical and horizontal acceleration up to
four
seconds.
No need for altitude effect on HP below 1000 feet.
This model needs to be refined to add the effects of gravity and
perhaps induced
drag due to lift. Gravity hardly affects the acceleration in
horizontal
mode and induced drag due to lift hardly affects it in vertical
mode.
I will probably assume the flight path is an arc consisting of one
quarter of a circle and calculate the various forces based on
that assumption. This is new to me but I am sure it was new to the
Osprey designers as well. I notice the Osprey starts moving
forward
almost immediately and within a few hundred feet of altitude.
I'll refine the model more later.
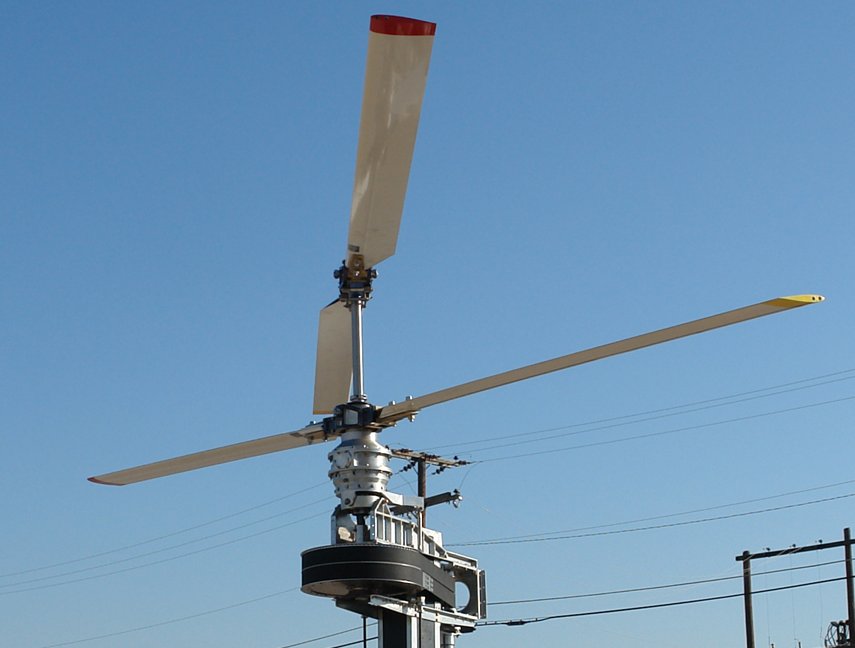
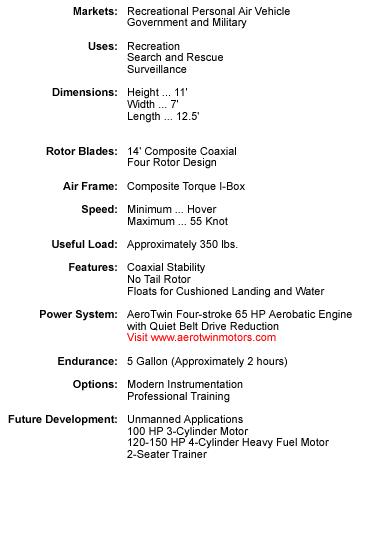
Here is a chart showing rotor diameter tip speeds using the
6.24 PSRU ratio. We are going to be limited to about a 12 to 14
foot
rotor due to the forward velocity vector adding to these tip
velocity numbers approaching Mach 1. That means the blade area must
be large
enough to absorb the HP available and provide the thrust required.
I am sure Perry is working on this as we speak.
The Osprey is affected by this same phenomena but it has the
advantages
of twice the disk area. The name of the game in vertical take off
is a low rotor disk loading.
The engine and rotor RPM will probably be forced to slow due to tip
mach effects
at WOT as the airplane pitches over and builds forward speed with a
consequent
loss in available Horse Power. Fortunately we don't need all
that HP
in forward
flight anyway nor do we want to run the engine at 8500 RPM
continuously.
We are very fortunate indeed to have a very low cost engine
with such
an exceptional power to weight ratio as the Mazda p-port Wankel
for this application.
--
Paul Lamar ...No rotor no motor.
The control surface on the canard (the elevator) will act as a
stator
vane of sorts. The size of this could be increased, and when in
hover
mode, the whole canard could be pitched to increase
effectiveness. It
will help the craft pitch over at a low speed, plus help in
very low
speed translational flight by vectoring the thrust created by
the rotor
disc. Further control could be achieved by adding a rhino rudder
(forward vertical stab) like a Rutan Defiant has.
As a side note, the Variezes and LongEZ's will recover from
tail slides
without undue drama - just pitch over and fly away.
Regards,
Matt-
I'm still playing with it. A lot of fun. After I get it flying well I'll
remove the landing gear and winglets and add the upper and lower
vertical stabilizers for landing.
Perry Mick
To amplify a bit, the control surfaces in the rotor blast will act like
the rudders on an airboat..
Matt-
Yes in theory but the old tail sitters had problems with that.
Deemed to be insufficient control. Also high technical risk as
one would need to do tether test which could be rather expensive.
I mention that in my article.
http://www.rotaryeng.net/STOL.html
The Air Scooter method is sure fire and proven to work.
I am still struggling with the blade length compromise and I
have slowly come to the conclusion what we need is a variable
length blade which would be another major breakthrough
in VTOL aircraft.
Paul Lamar ...No rotor no motor.
The Rotary Engine NewsLetter. Powered by Linux.
ACRE NL web site.
http://www.rotaryeng.net
Copyright 1998-2006 All world wide rights reserved.