I was thinking how easy it would be to build
an auto land system.
Anybody know how to program Android apps?
All you need is a tablet with a USB port and moving map software.
Then you build a pressure altimeter using a single
chipper and a pressure sensor with a USB interface.
The GPS is built into the the tablet.
You set the coordinates of the end of the runway you want to land
on and that will put you within 15 feet.
The last little bit is done with a ultrasonic back up sensor.
Paul Lamar
I want a GOOD autoland system.. ;)
Actually, I don't. I like landing airplanes by use of my hands, feet, and eyes. It's fun.
Matt-
OK Cat IIIB but low cost :) Of course it is not legal but who is going to bust you landing on a
private strip with no ILS.
Hands, feet, and eyes work until you can't see and there is no ILS.
Paul Lamar
Hi!
Maybe a good solution for reliable altitude measurement.
http://lea.hamradio.si/~s53mv/radalt/radalt.html
Viktor
Maybe not a full auto pilot at first.
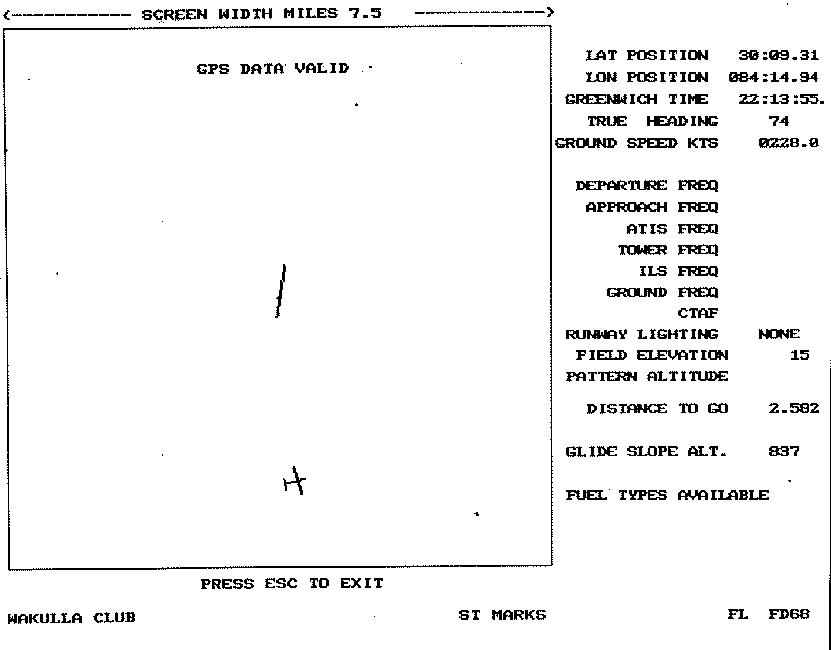
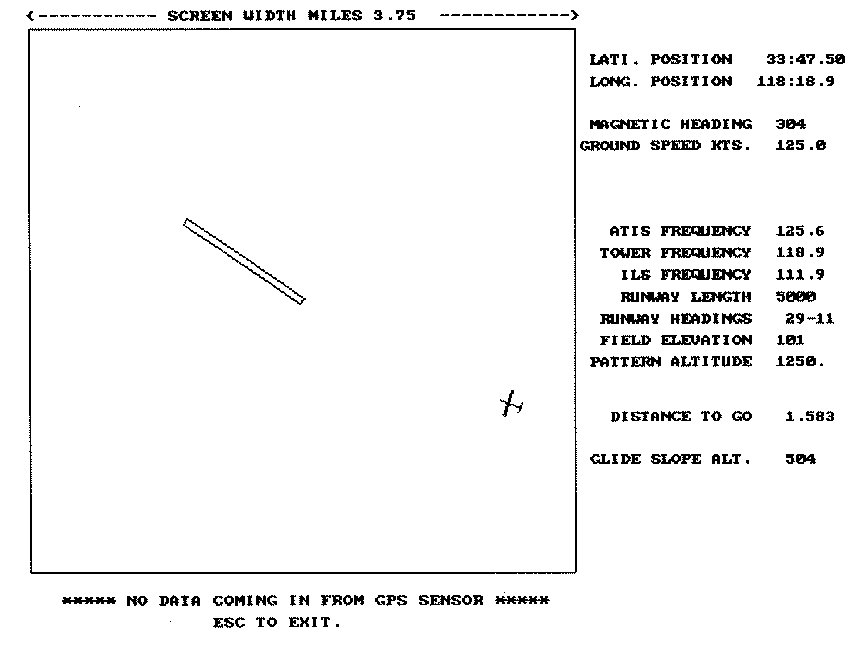
Just have the computer calculate the glide slope or rate of descent required based
on the GPS distance data and altimeter data to the runway threshold.
Sort of a hand flown GCA. Old ground radar based Ground Controlled Approach.
I did that back in the early 1990's but the computer merely calculated
the altitude you should be at if you were on a 3 degree glide slope. It was
up to the pilot to read the panel altimeter and see if he was above or below
the 3 degree glide slope and adjust altitude accordingly. The moving map GPS out
put gave the proper direction to the threshold. Actually the map was stationary and
the airplane symbol moved on the screen
It was written in QB for DOS. It would have to be translated to Java.
Paul Lamar
--
The Rotary Engine NewsLetter. Powered by Linux.
ACRE NL web site.
http://www.rotaryeng.net
Youtube key word PaulLamar2
Copyright 1998-2011 All world wide rights reserved.