Hi Terry Im interested in rolling my own flap and trim control. Are
you willing to share your setup and code design.
Steve Izett
Steve, what board are you planning to use? I have a program that I
wrote for an Arduino Mega that reads a POT connected to the flap
actuator and activates an H bridge. It works- press the down button
and get 10 degrees, press it again get 20 and the third time get max,
which on my plane is 40. Press it once and it goes up a notch, etc. I
have tried to put it on an Uno or Tiny and it doesn't work just
right, but on the Mega 2560 it works fine.
I re-purposed a pair of Microsoft joysticks for my sticks- the center
joystick is elevator and aileron trim, the buttons on the left are up
and down flaps, and the buttons on the right are interior lighting.
The thumb button is autopilot off and on. The trigger is PTT. Works
great.
If anybody wants more info, shout at me.
Let me know if this will work for you-
Kevin Alderman
Hi Kevin
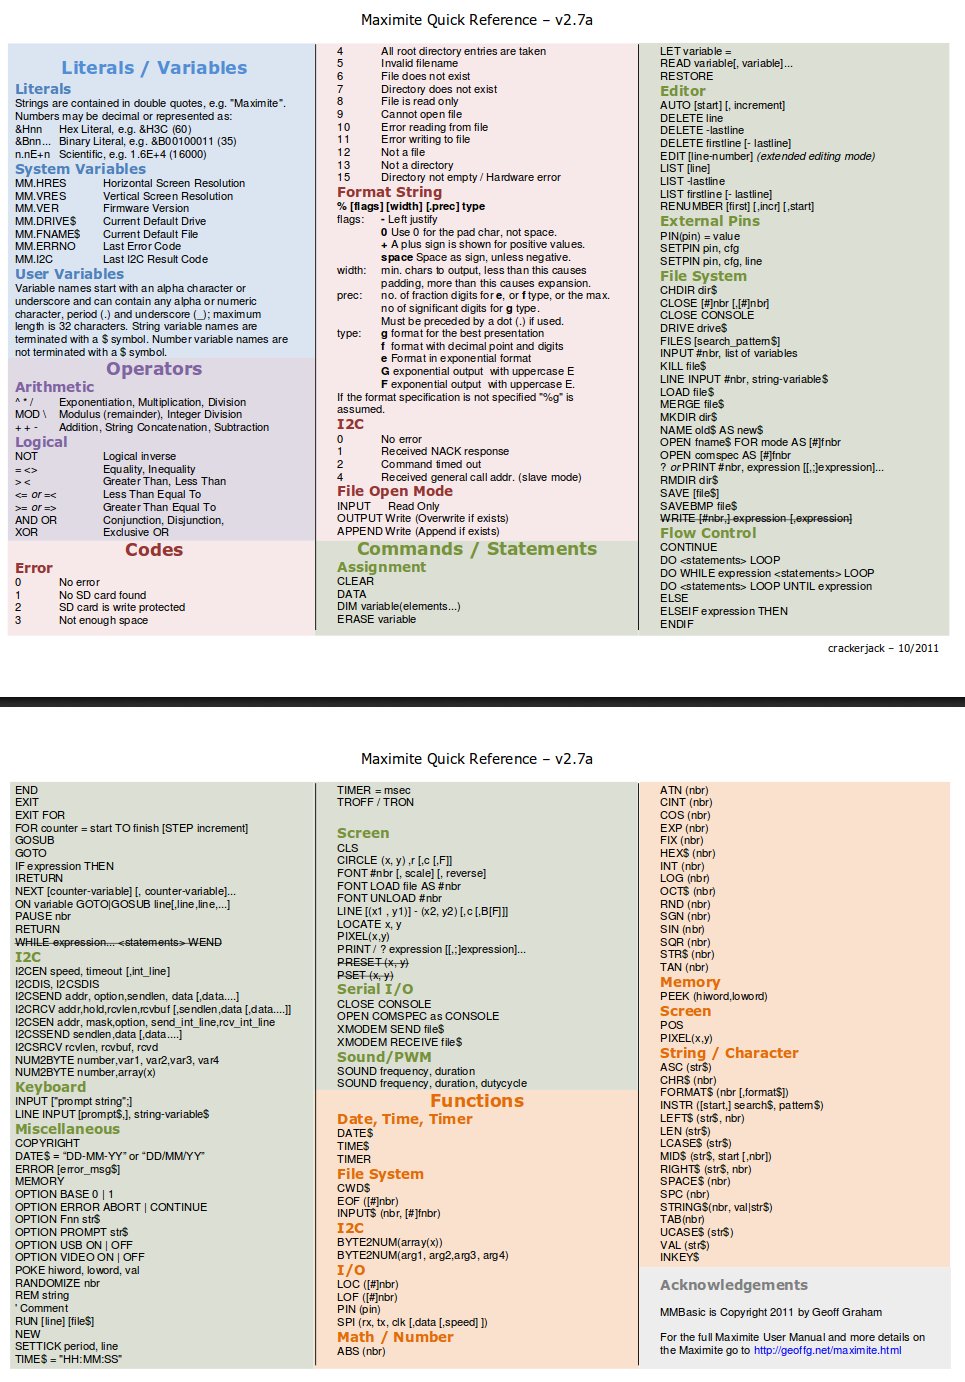
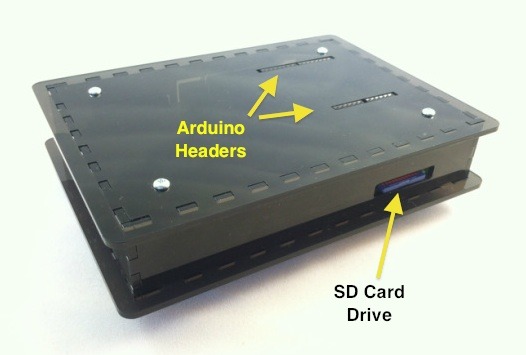
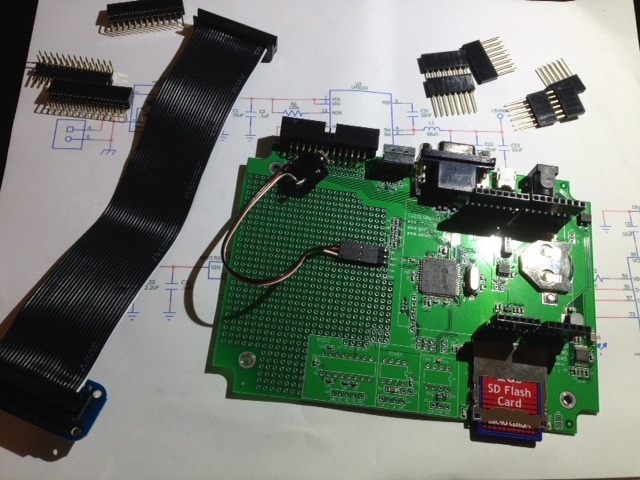
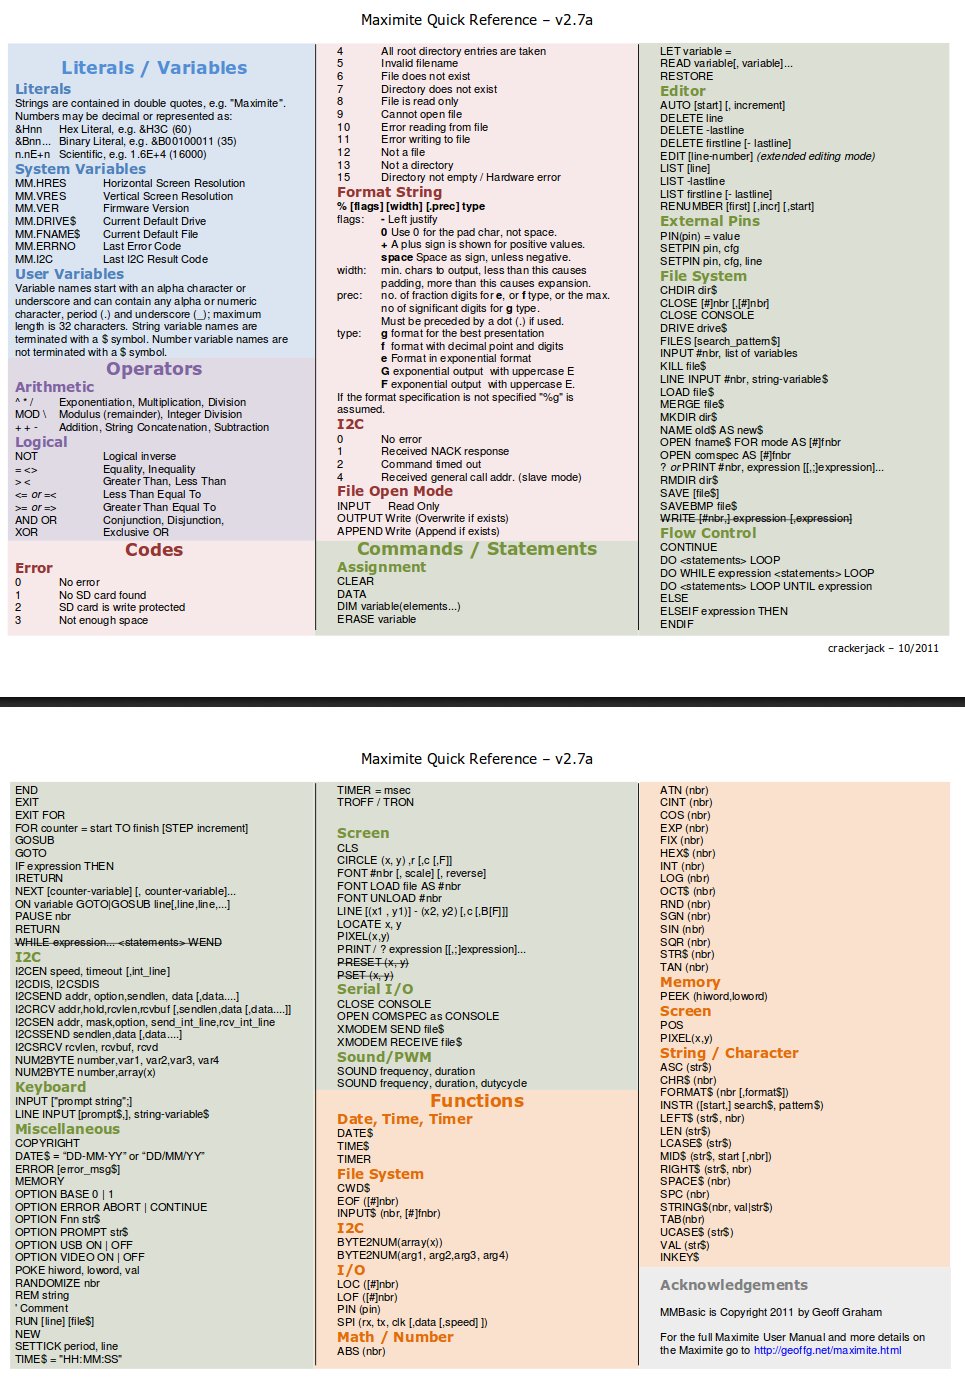
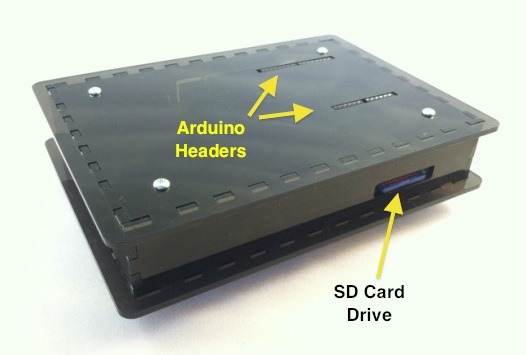
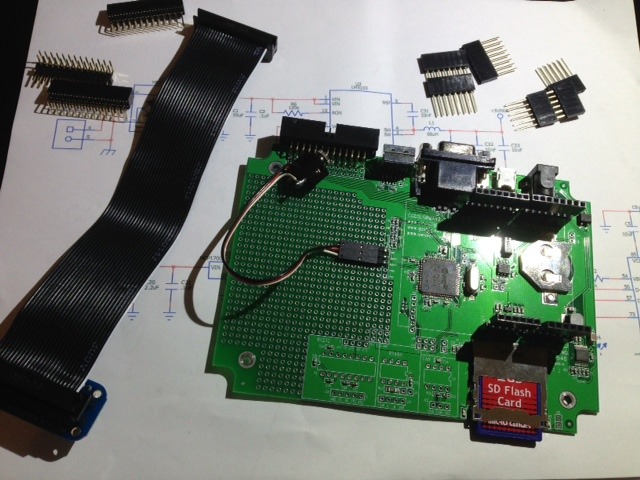
Thanks for the feedback. I’m using the Colour Maximite which used
interpreted basic script.
Your flap control is similar to what I plan to do. A few lines of code
with a pot as feedback.
I’m interested in automating the pitch trim and wondering whether air
speed, flap position and weight and balance
will be consistent data to reliably adjust trim, or will it require
feedback from the autopilot system?
If it requires data from the skyview bus then that puts it beyond my
time/ability/risk decision matrix.
Cheers
Steve Izett
https://www.kickstarter.com/projects/818225433/maximite-bbx-the-modern-day-basic-language-compute
Wow!
That is really cool Steve.
I got to get one and try it out.
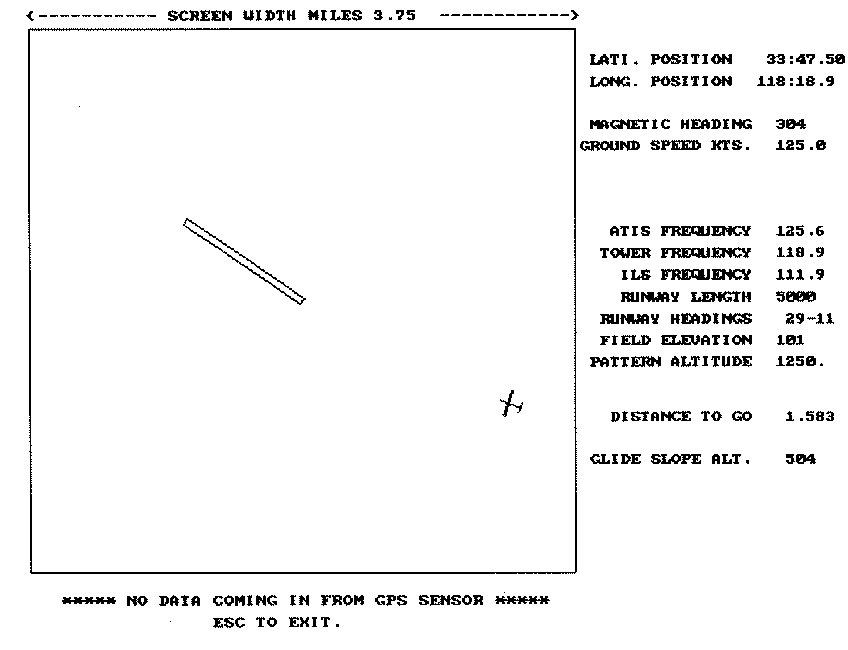
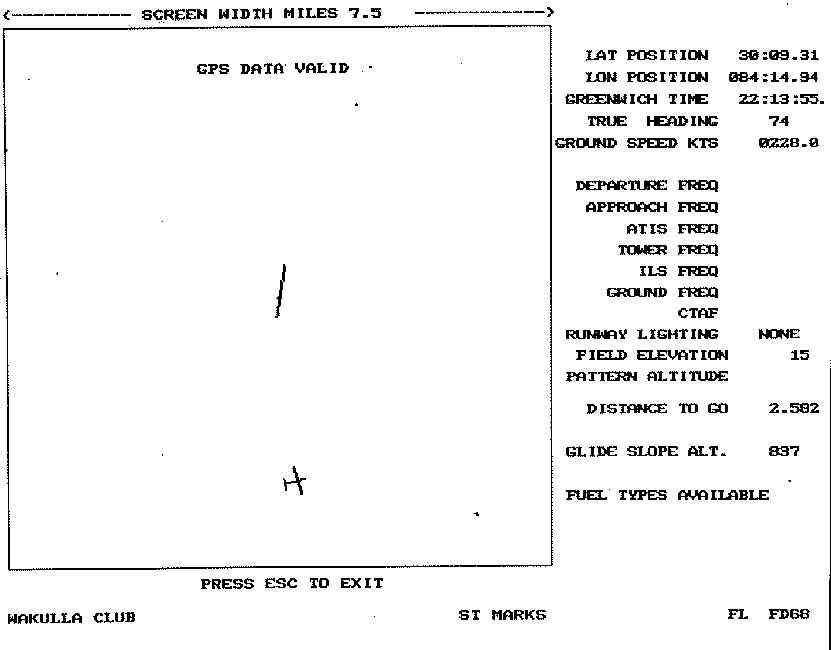
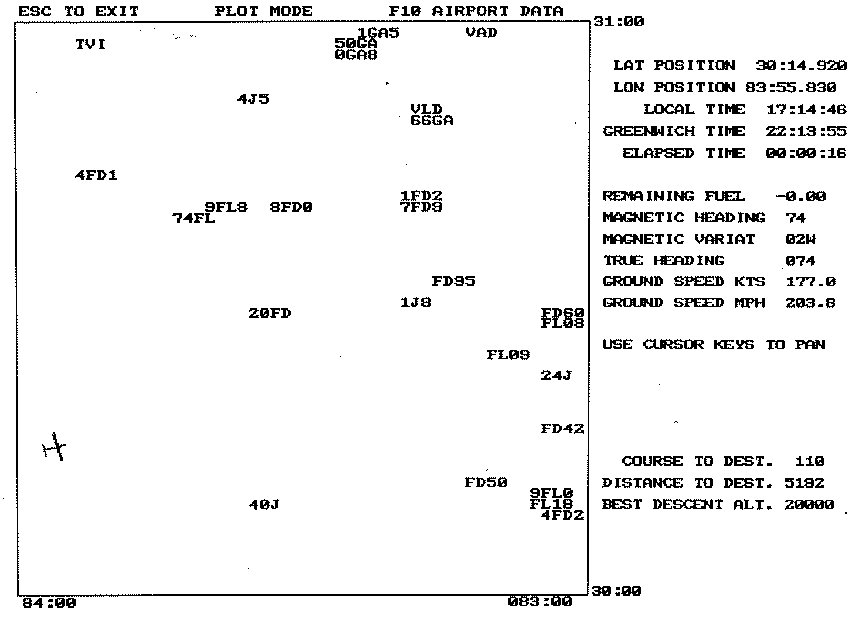
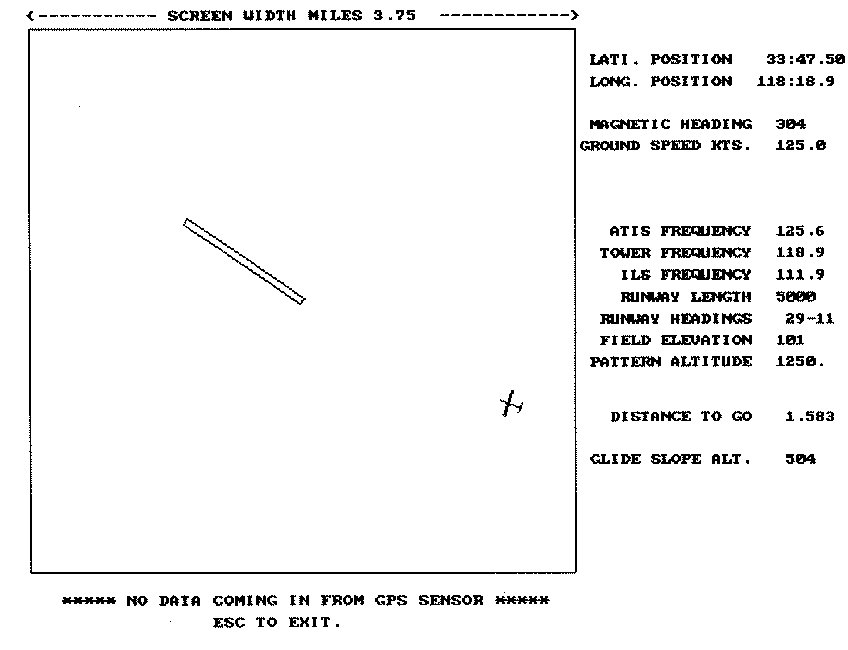
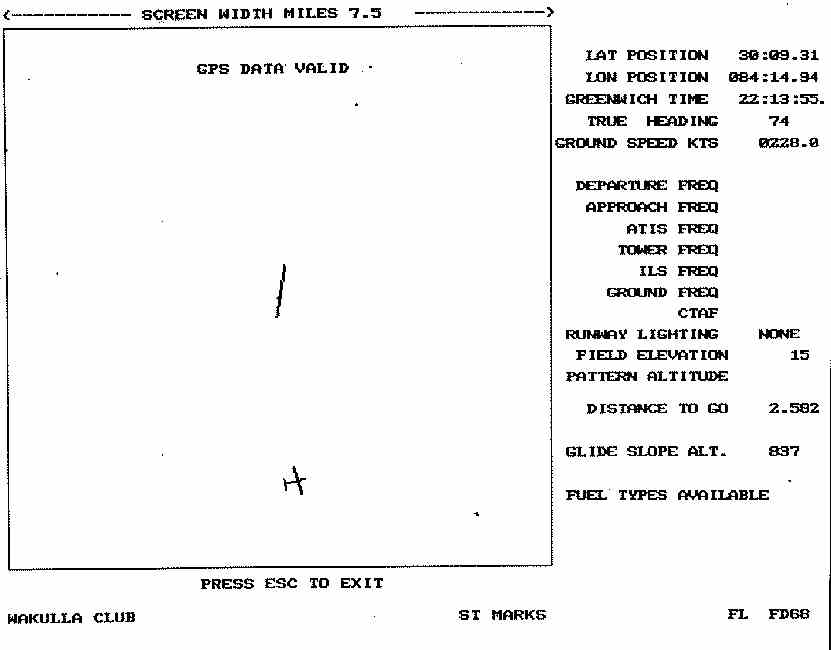
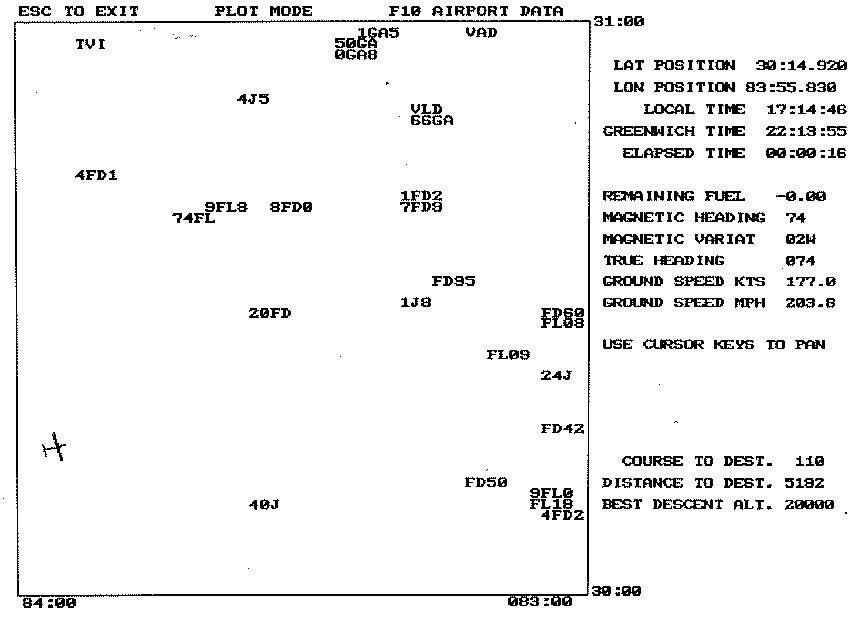
Looks like I can port my GPS driven Moving Map software
I wrote in 1990.
Finally one can write real time software on this jewel.
Paul Lamar
The Rotary Engine News Letter. Powered by Linux.
ACRE NL web site.
http://www.rotaryeng.net
You Tube
http://tinyurl.com/beqqxas
Copyright 1998-2014 All world wide rights reserved.