Getting up too speed on my LinuxCNC installation and I ran across this well
written explanation of why Windows does not work for machine control
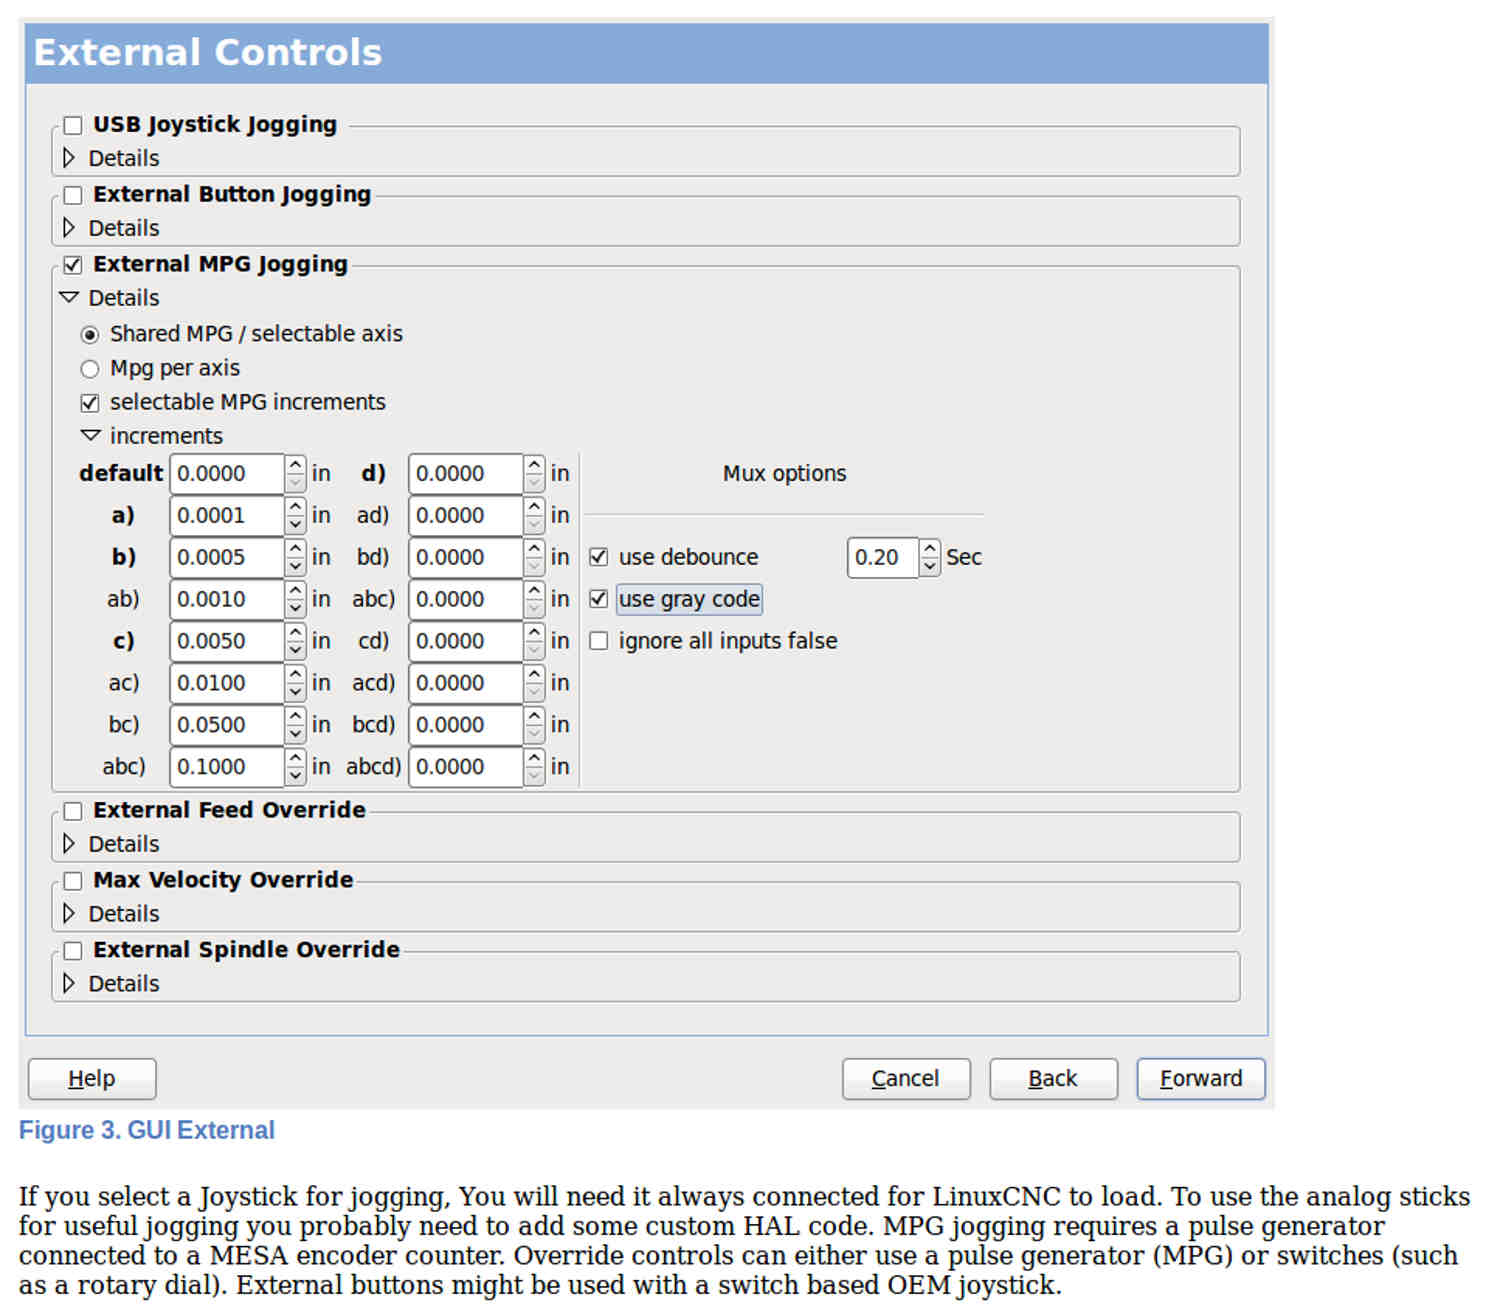
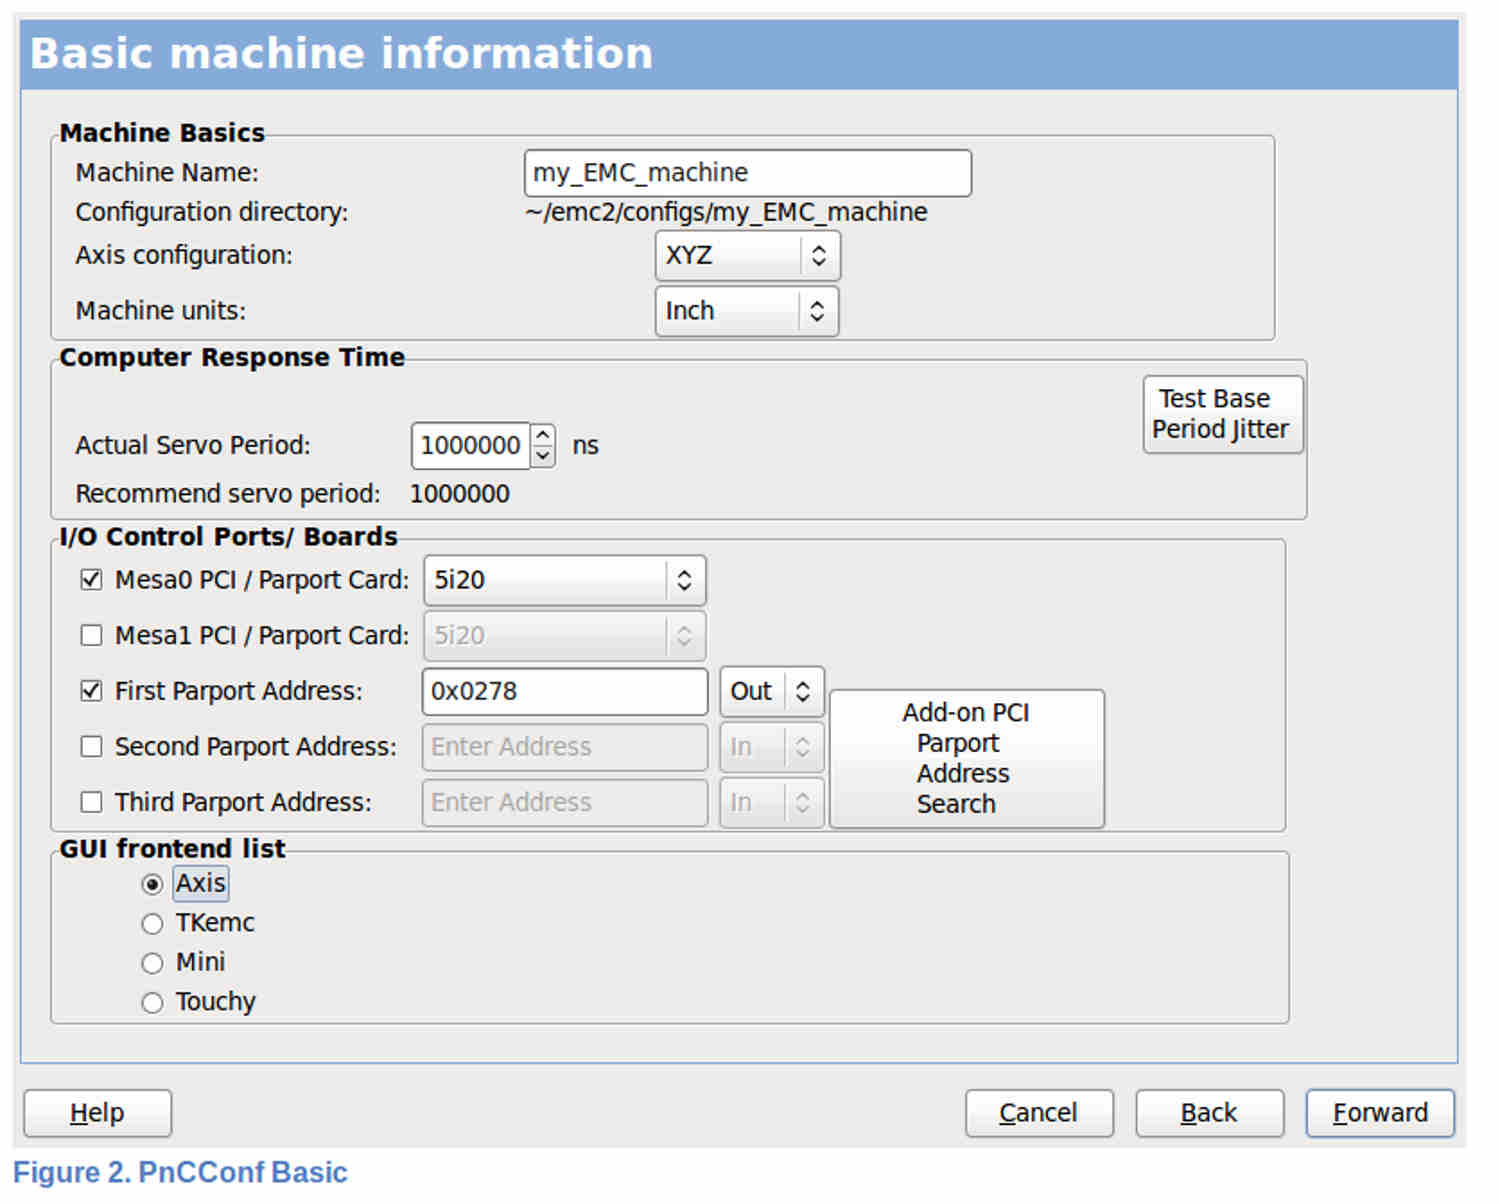
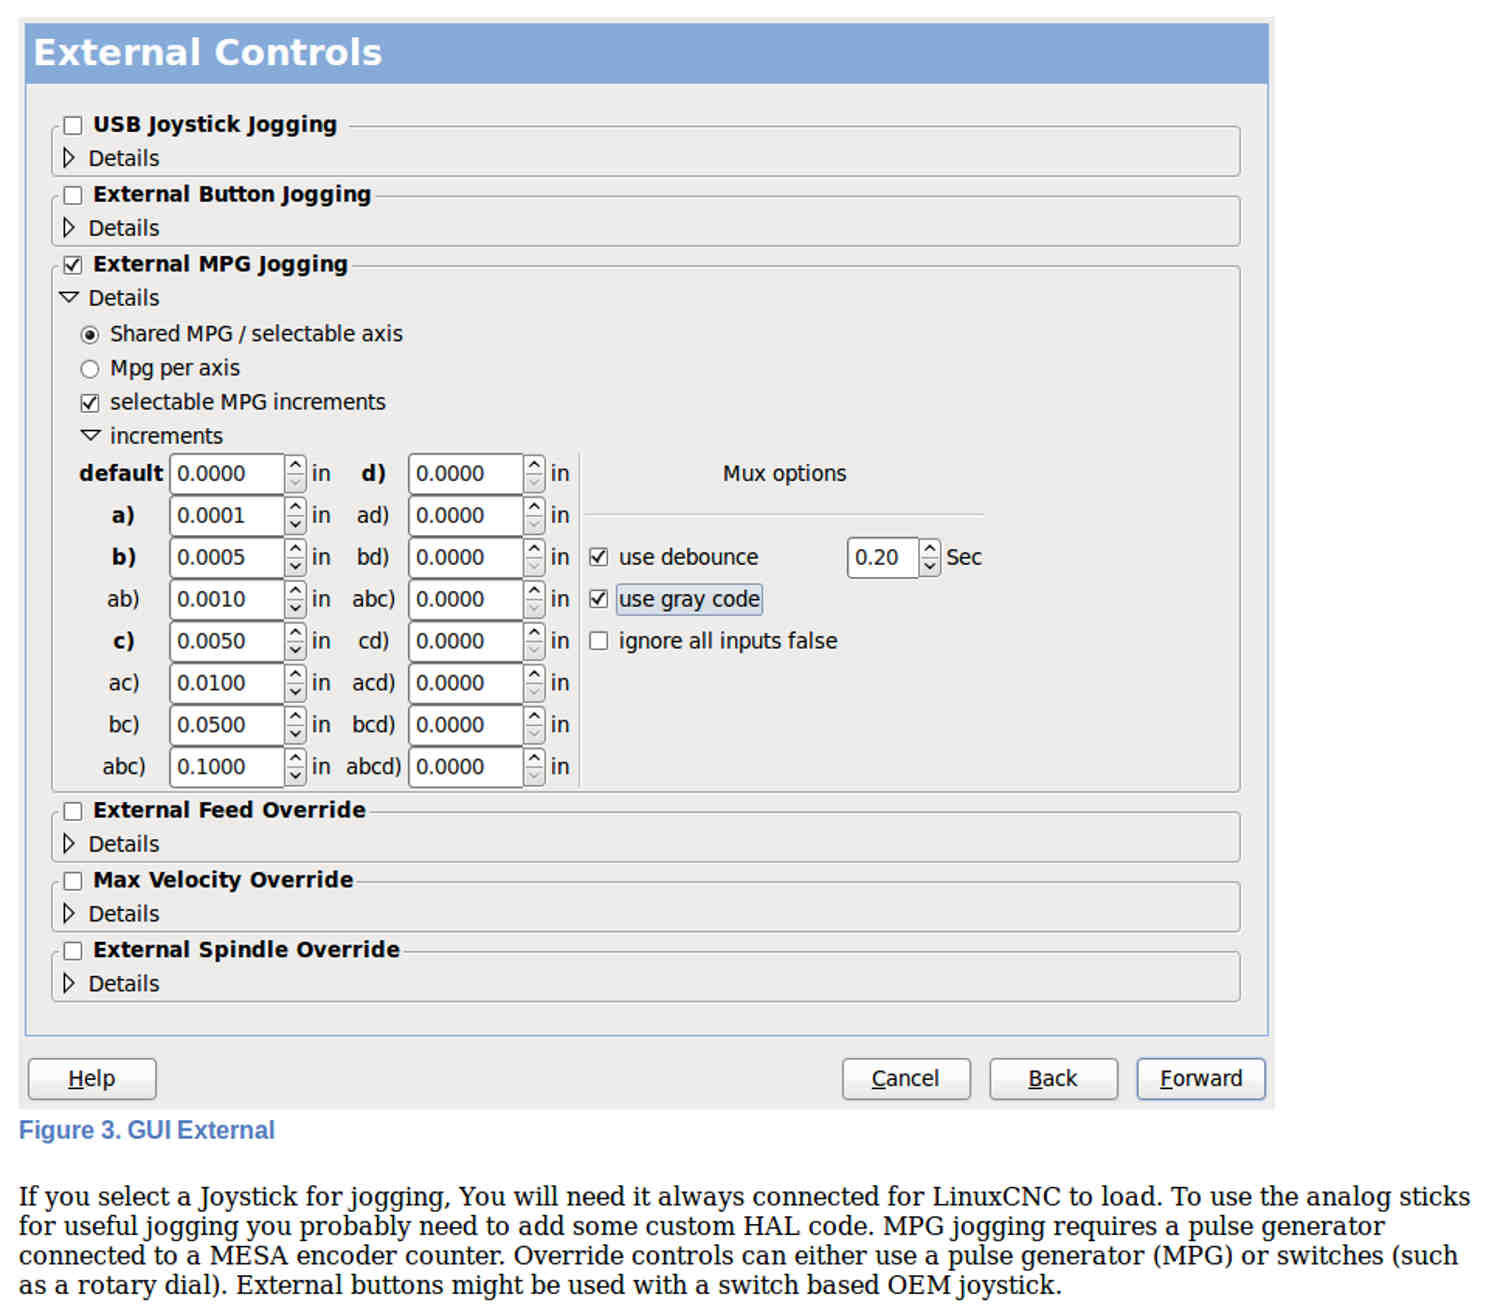
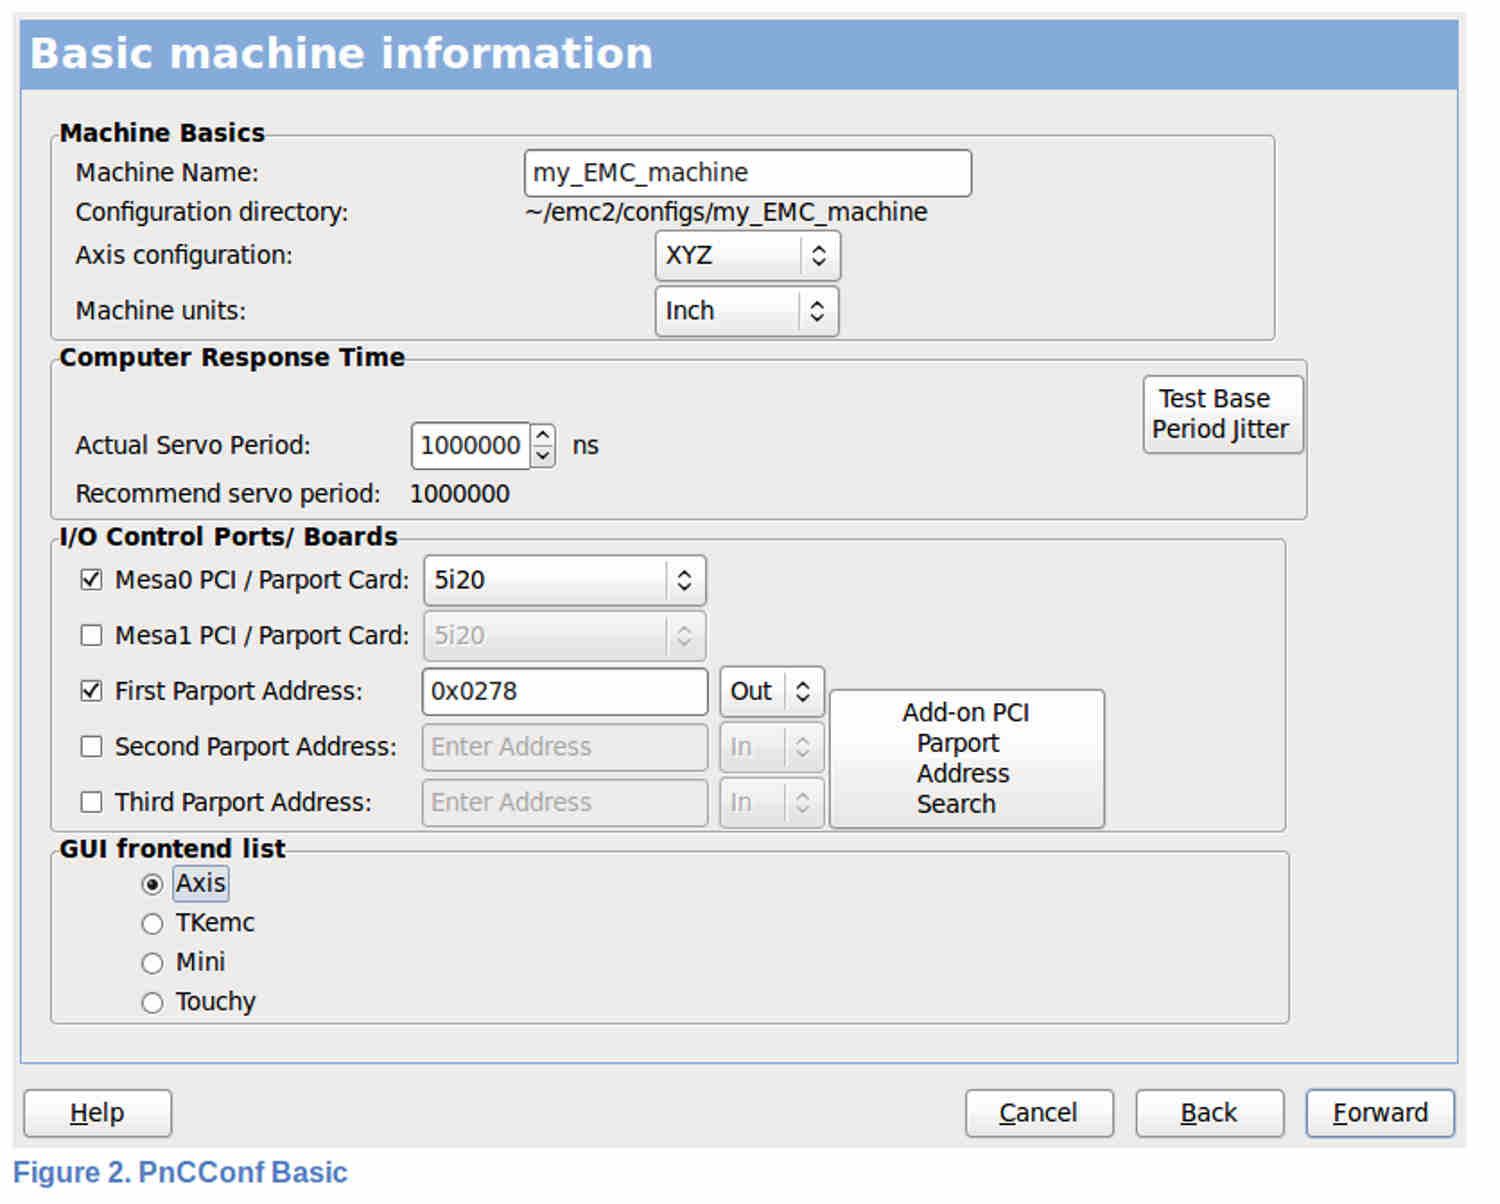
in pncconf.pdf. (attached)
The Maximite and DOS QB do not have this problem.
Way back in in 1975 when I wrote a hardware interrupt driven multitasking
OS for my Road Test system I figured this out. I designed a priority encoder
for the hard ware interrupts using discrete integrated circuits. This
was years
ahead of it's time. Only in the past 20 years or so has this implemented in
microcomputers like the PIC and ARM and I suspect it is yet to be
implemented
in Intel products. The pulse from the speed sensor had the highest
priority in the Road Test system. I looked like an idiot Muslim in those
days :-(
http://www.rotaryeng.net/RT1.pdf
"The servo period sets the heart beat of the system. Latency refers to
the amount
of time the computer can be longer then that period. Just like a rail road,
LinuxCNC requires everything on a very tight and consistent time line or bad
things happen. LinuxCNC requires and uses a real time operating system,
which
just means it has a low latency ( lateness ) response time when
LinuxCNC requires its calculations and when doing LinuxCNCs calculations
it cannot be
interrupted by lower priority requests (such as user input to screen
buttons or
drawing etc)."
Paul Lamar
The Rotary Engine News Letter. Powered by Linux.
If you want off the list PLEASE let me know and I will
remove you. ACRE NL web site.
http://www.rotaryeng.net
You Tube
http://tinyurl.com/beqqxas
Copyright 1998-2015 All world wide rights reserved.